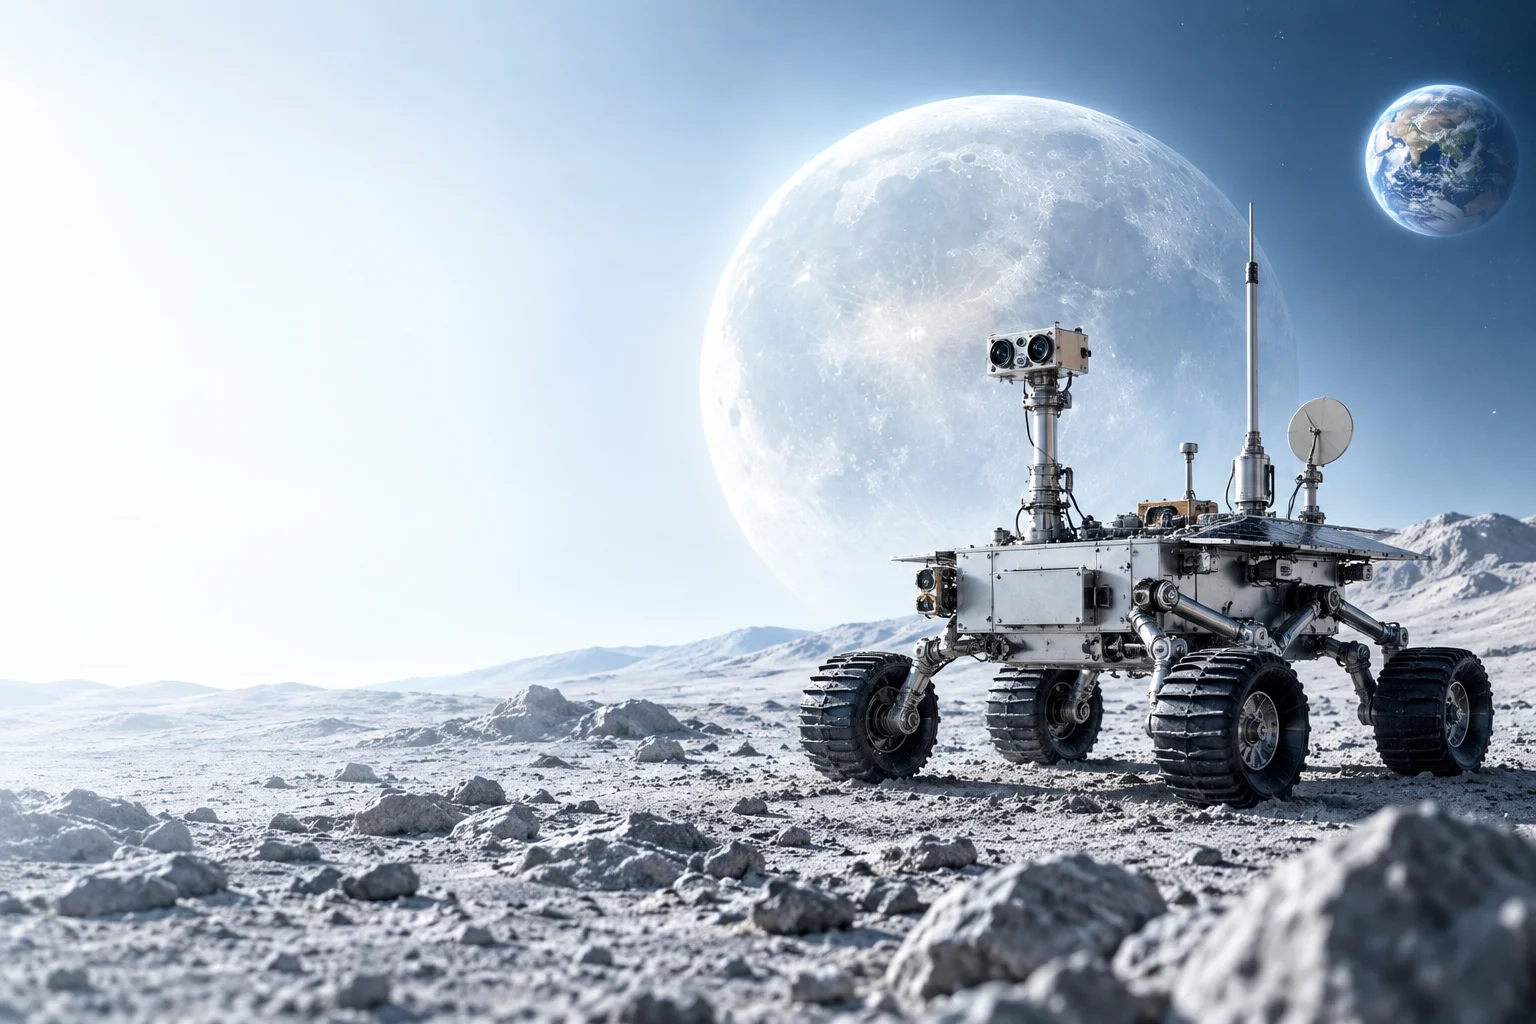
Small rover. A lot of learning. This week’s idea: a navigation stack that keeps going when GPS isn’t an option. Starting with visual odometry and a very patient test plan. The image is the kind of mission that keeps me motivated. Builders: what would you prototype first — perception, localization, or control?
56 reactions0 comments